Overview
The Drover explores a transformable platform that can drive across terrain and mechanically reconfigure toward an aerial transition.
Solo project
Hybrid rover/drone prototype exploring transformable mobility, servo-actuated wheel geometry, and embedded flight-control foundations.
Project Summary
A short look at the build, the main technical choices, and the pieces I iterated along the way.
The Drover explores a transformable platform that can drive across terrain and mechanically reconfigure toward an aerial transition.
I designed the chassis, built the servo-actuated wheel camber mechanism, packaged BLDC propulsion into the transformable platform, and developed the embedded control direction for repeatable configuration changes.
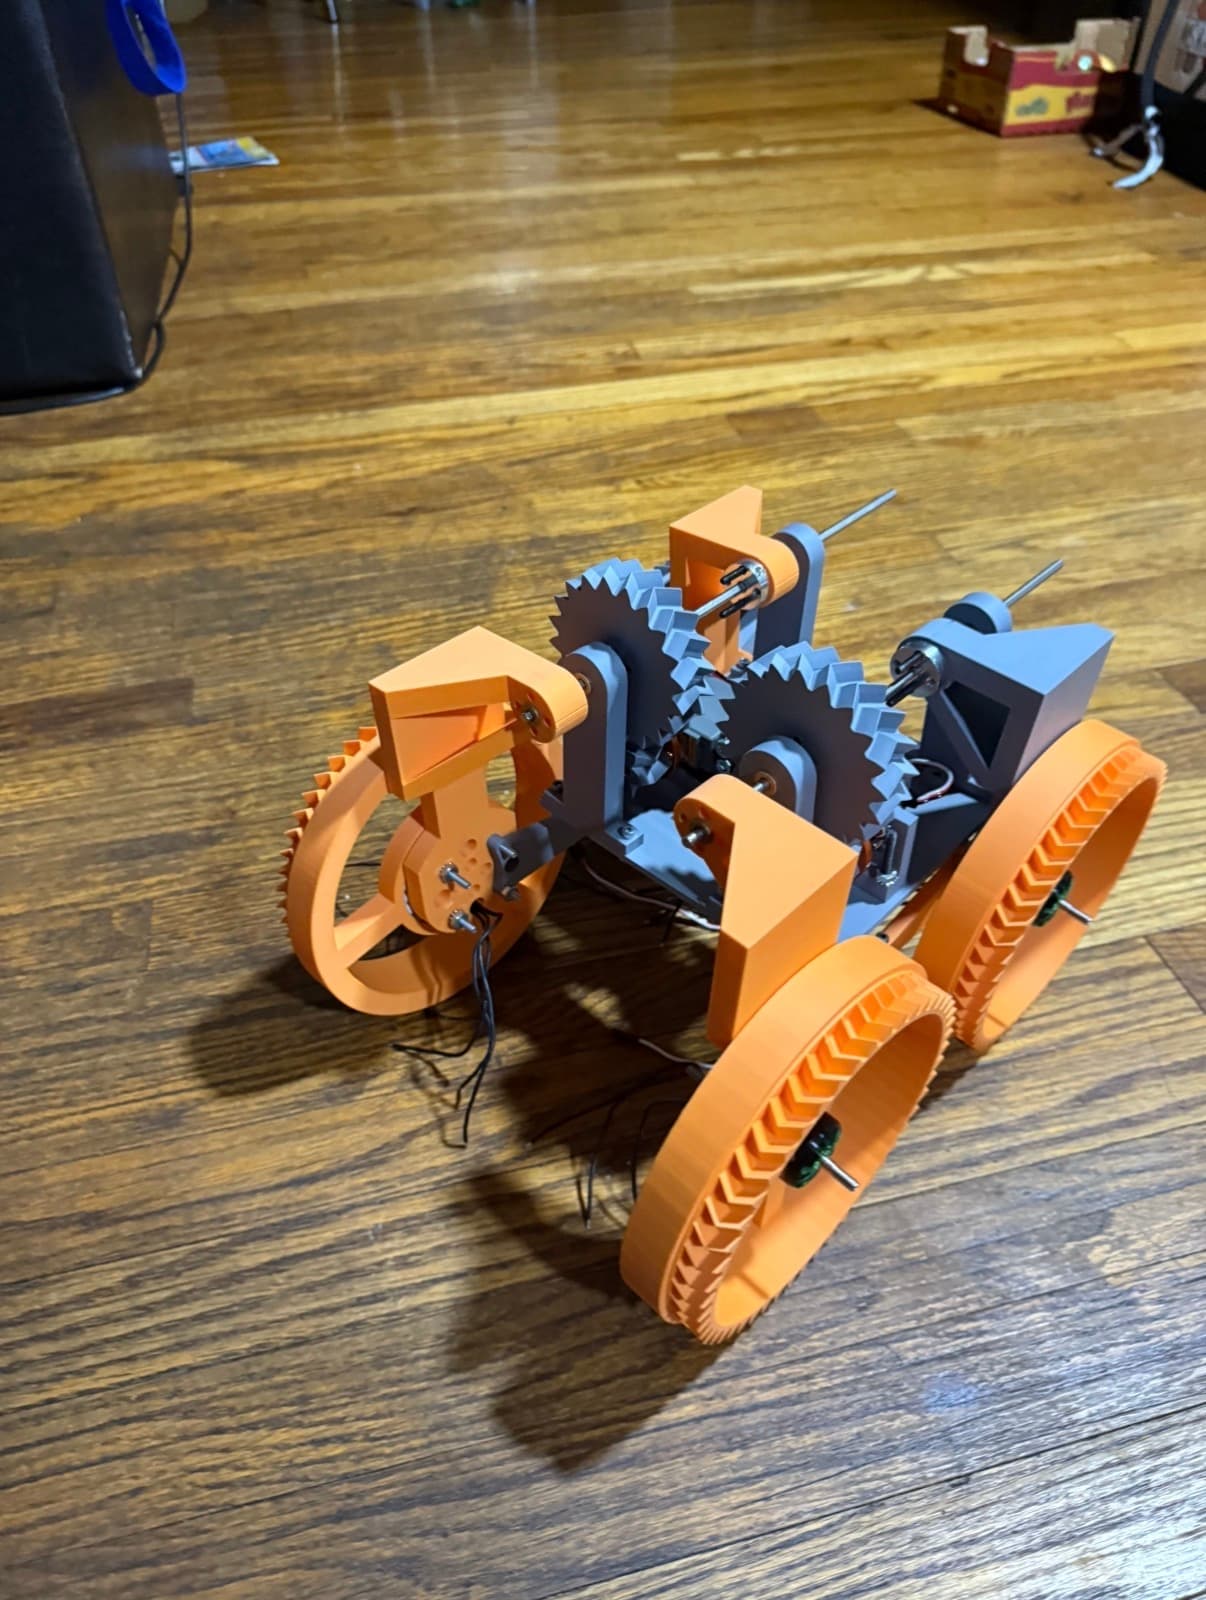
The build progressed through a V1 half-chassis prototype, a V2 driving rover iteration, and herringbone gear press-fit design, ending in a merged final assembly video showing how the completed mechanism comes together.
Demos
Videos and images from the current build, earlier iterations, and the small details that shaped the project.
Latest Drover build photo used as the current visual reference for the platform.