Overview
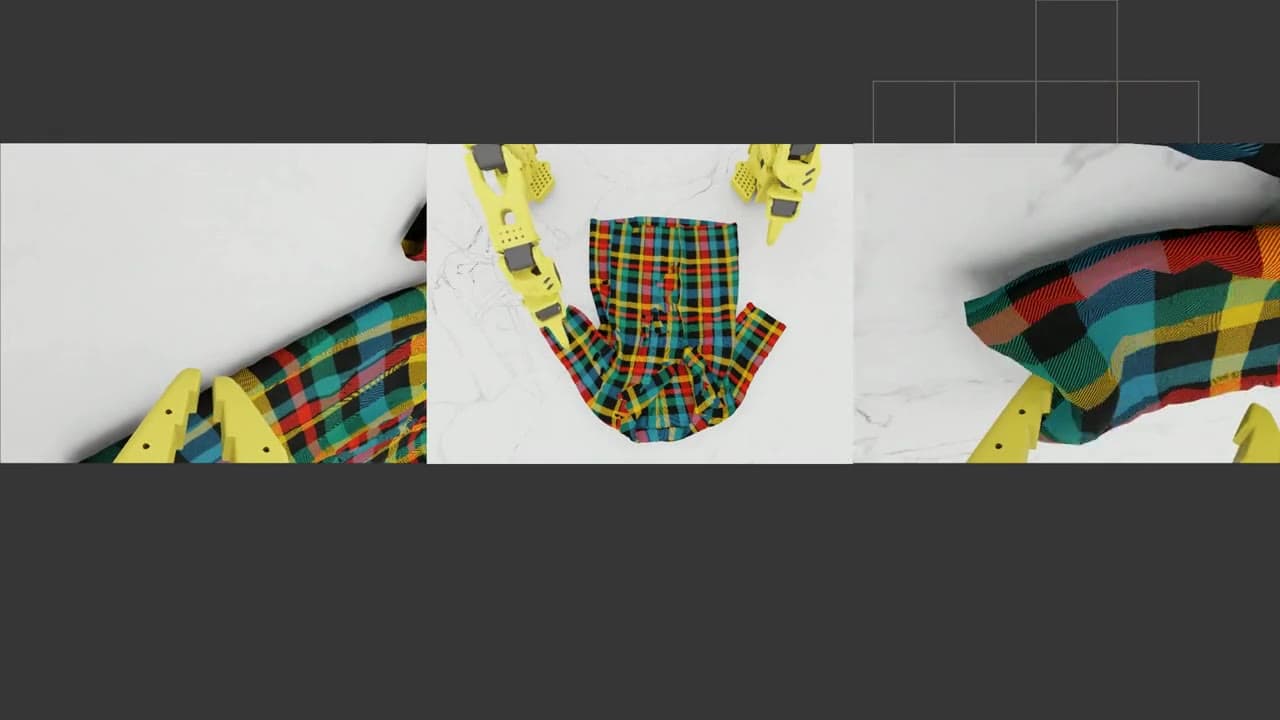
LeHome is a robot-learning competition entry that teaches a bimanual robot to fold laundry in simulation, training imitation and VLA policies to handle a range of garments.
Partnered with Kenta Terasaki
Isaac Sim and Isaac Lab training pipelines for bimanual simulated manipulation in the LeHome Robotics Simulation Competition.
Project Summary
A short look at the build, the main technical choices, and the pieces I iterated along the way.
LeHome is a robot-learning competition entry that teaches a bimanual robot to fold laundry in simulation, training imitation and VLA policies to handle a range of garments.
I built Isaac Sim / Isaac Lab training pipelines, trained ACT and diffusion policies with PyTorch on A100 GPUs, and fine-tuned VLA models including SmolVLA and Pi0-FAST with Hugging Face Accelerate.
The core technical work is scalable robot-learning infrastructure for simulated manipulation across garment categories: short sleeves, long sleeves, shorts, and pants, with robot-view videos for each.
Demos
Videos and images from the current build, earlier iterations, and the small details that shaped the project.