Overview
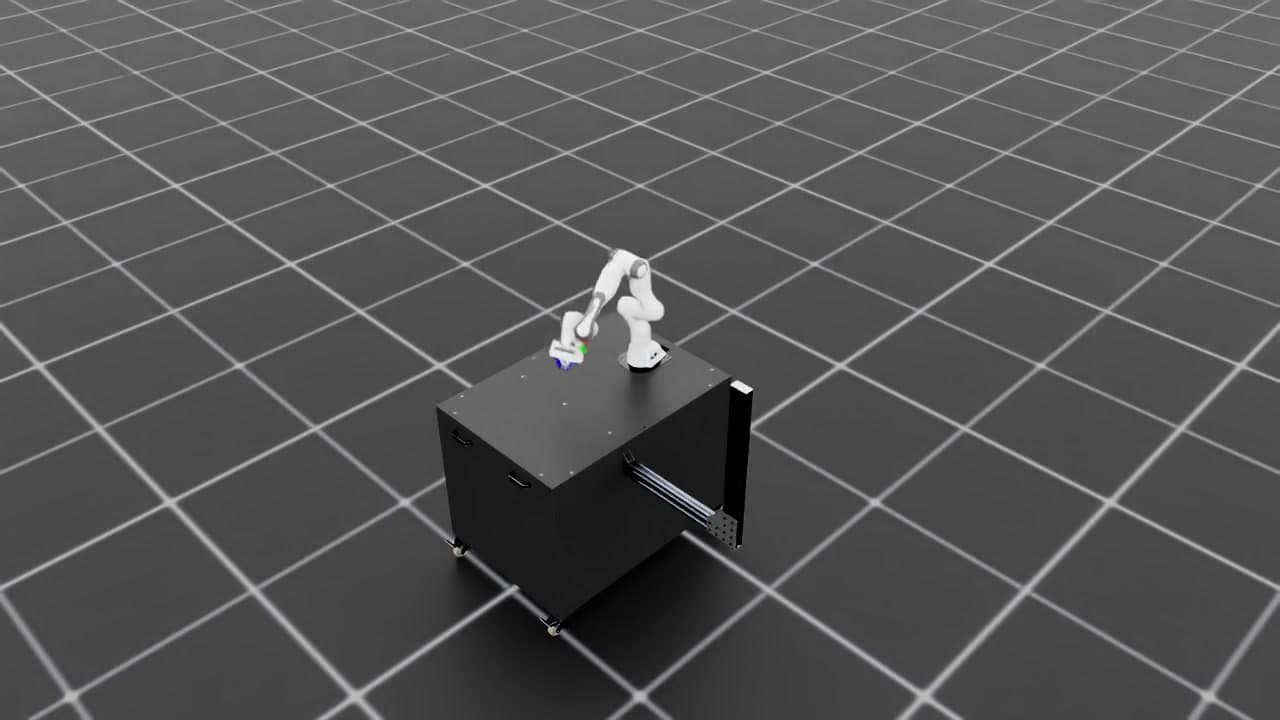
This project studies end-effector control for a Franka Panda arm tracking a time-varying figure-eight trajectory in Isaac Sim / Isaac Lab.
Solo project
Custom Isaac Lab reinforcement-learning environment for training a Franka Panda arm to track time-varying Cartesian figure-eight trajectories with smooth, stable motion.
Project Summary
A short look at the build, the main technical choices, and the pieces I iterated along the way.
This project studies end-effector control for a Franka Panda arm tracking a time-varying figure-eight trajectory in Isaac Sim / Isaac Lab.
I built a custom Isaac Lab task for Franka figure-eight tracking, trained PPO policies with joint-position control, and wrote evaluation tooling for simulator videos, XY tracking GIFs, diagnostics, and summary metrics.
The work compares single-frequency, multi-frequency, noisy, and delayed variants across 0.25–1.00 Hz trajectories, including Gaussian sensor noise and randomized 16.7–33.3 ms actuator delays.
Demos
Videos and images from the current build, earlier iterations, and the small details that shaped the project.
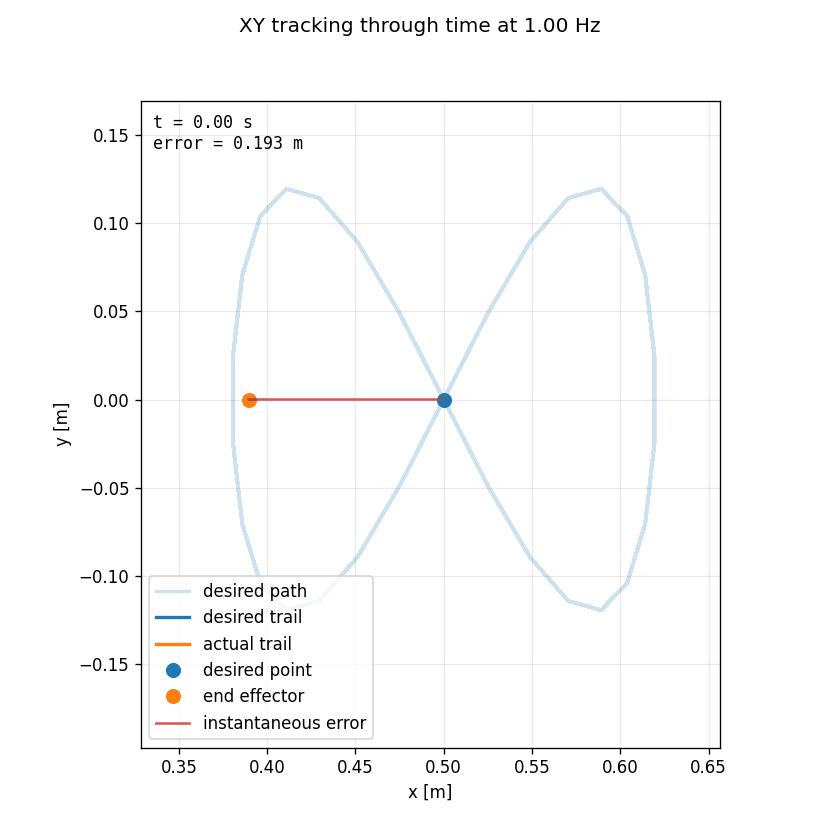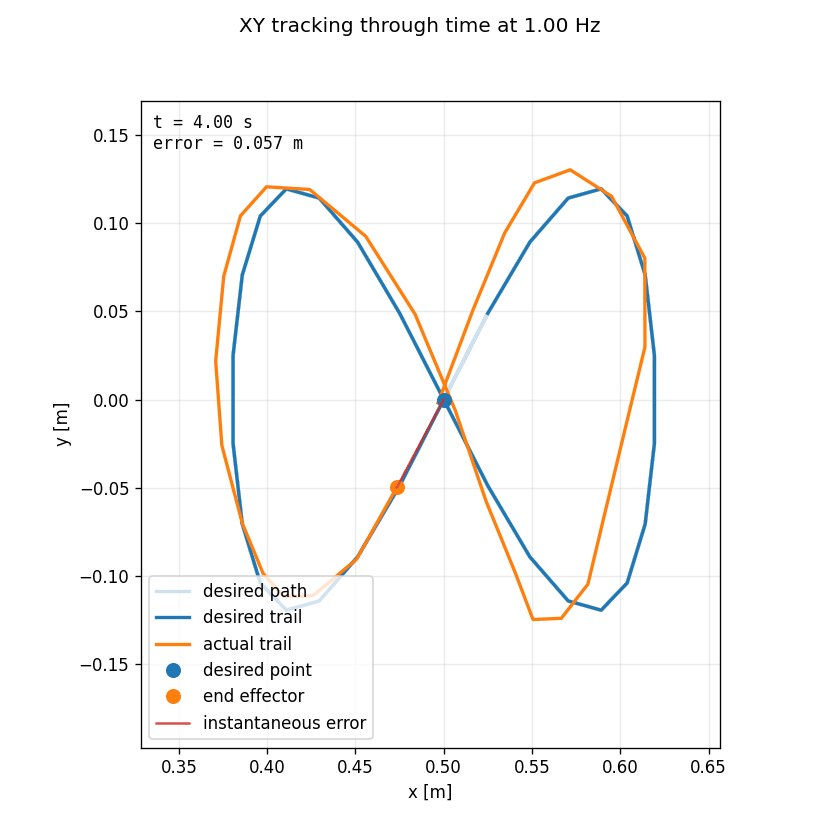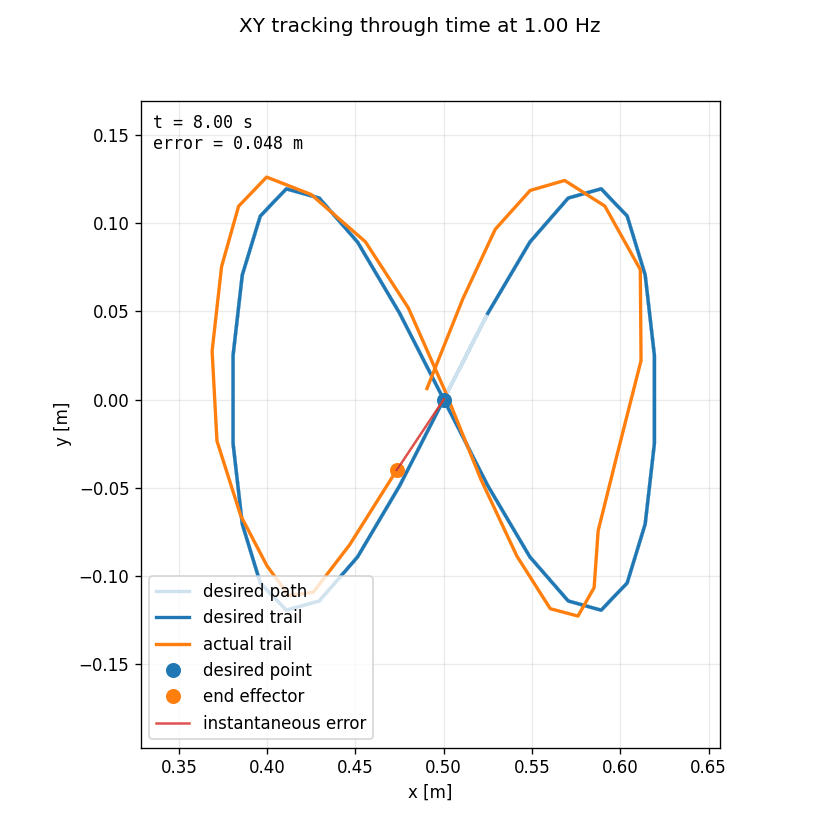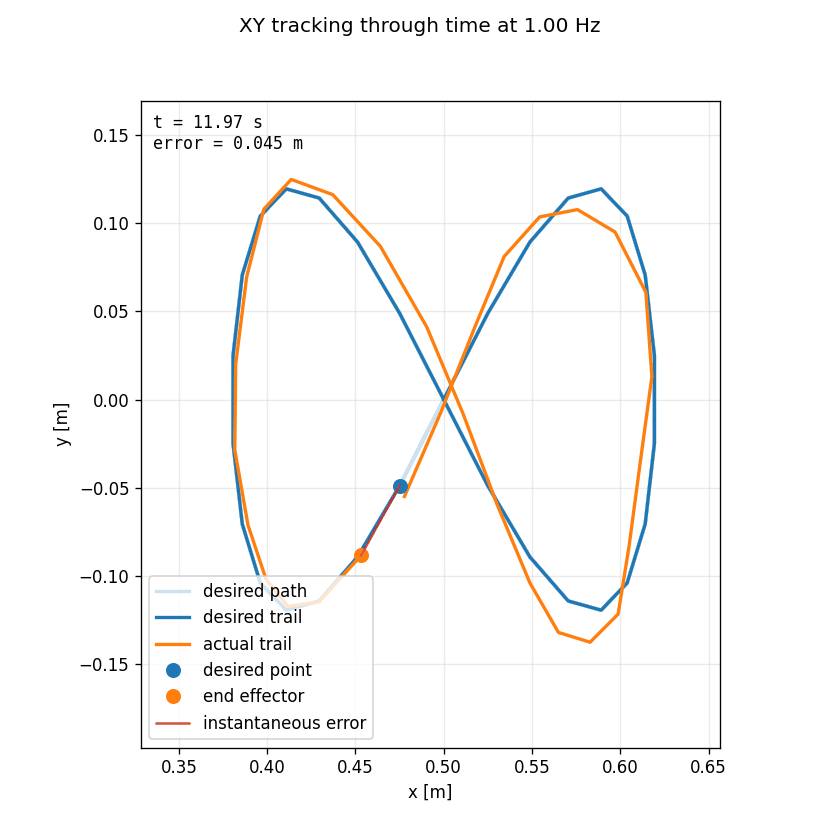
Animated Figure-8 point tracking trace showing the target-following behavior in the XY plane.
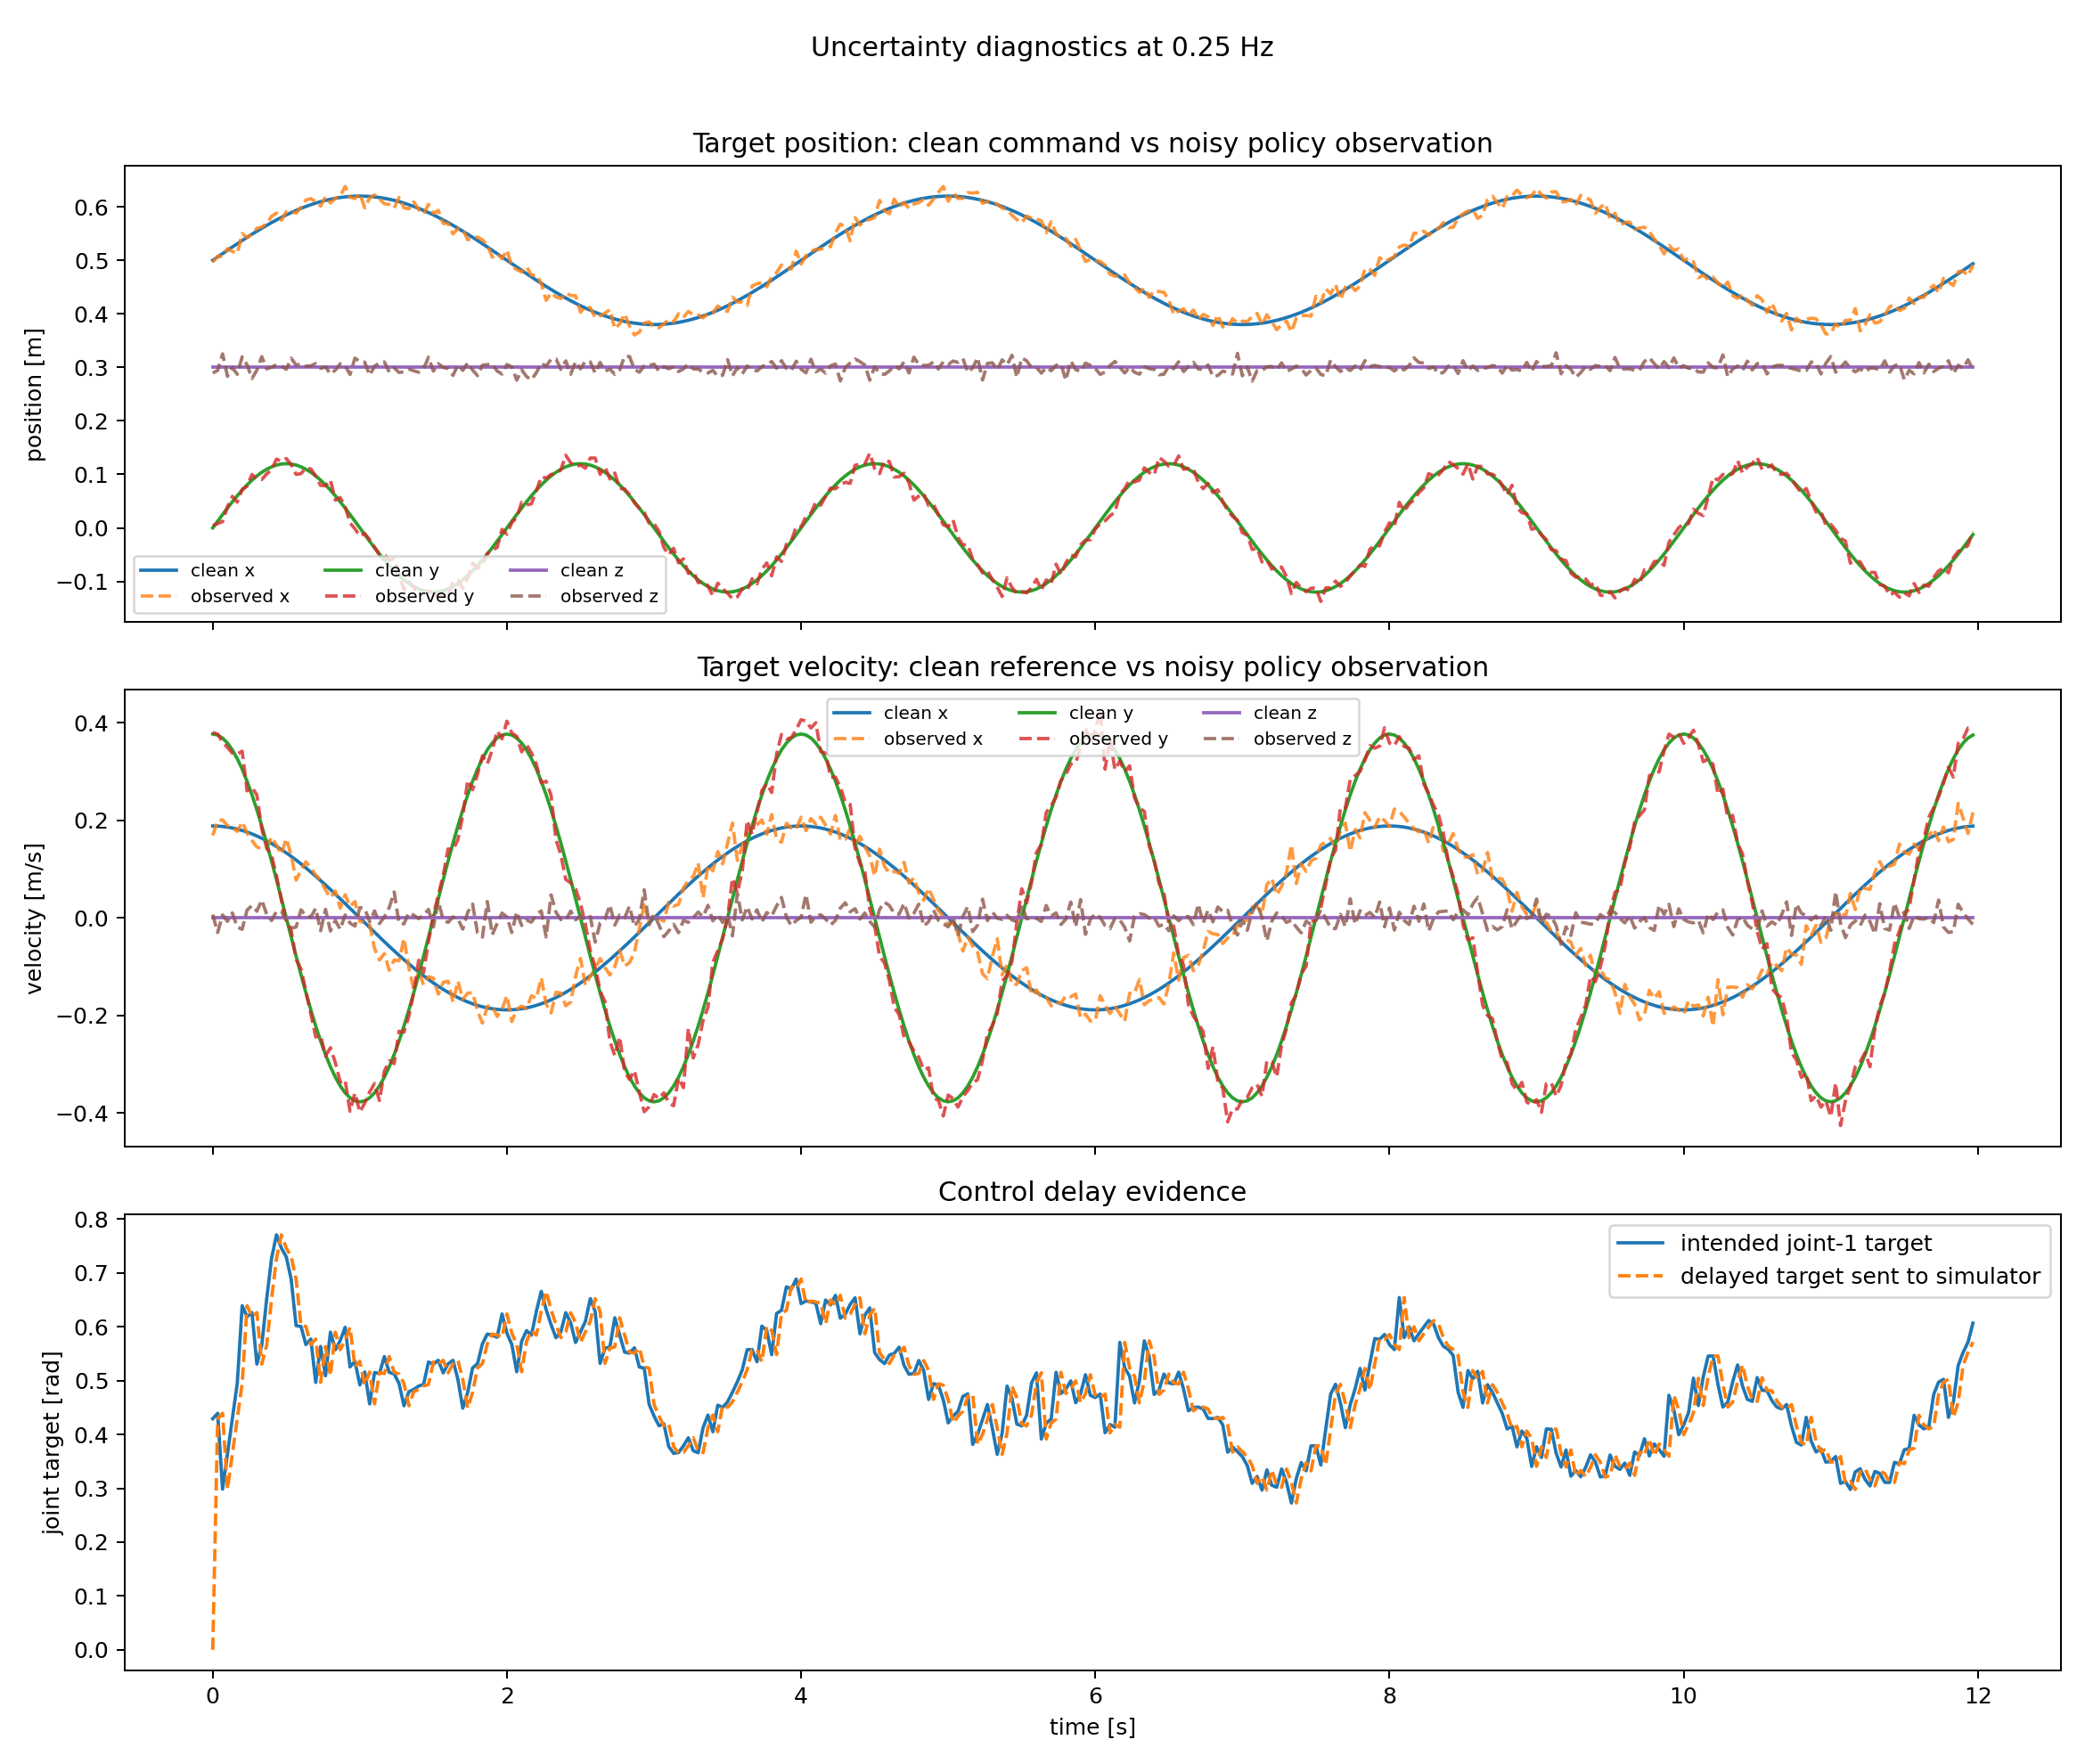
Diagnostic plot used to inspect tracking noise, target behavior, and controller response at the slow command speed.