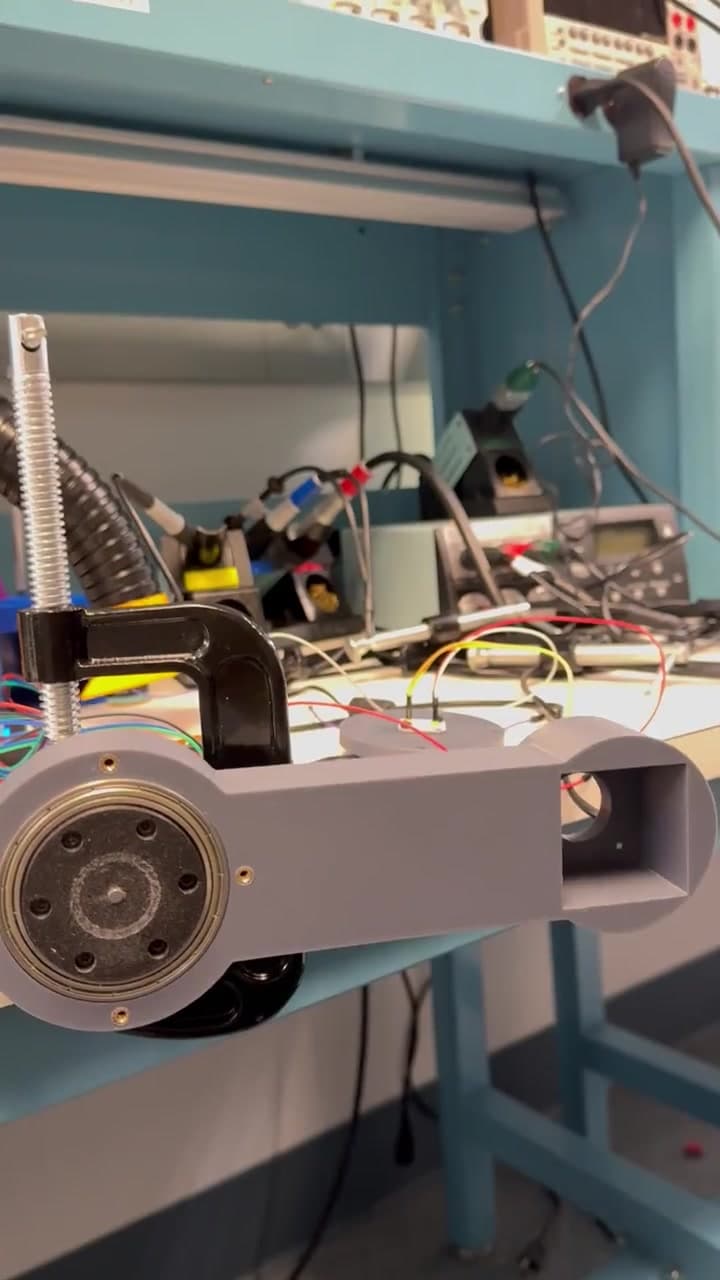
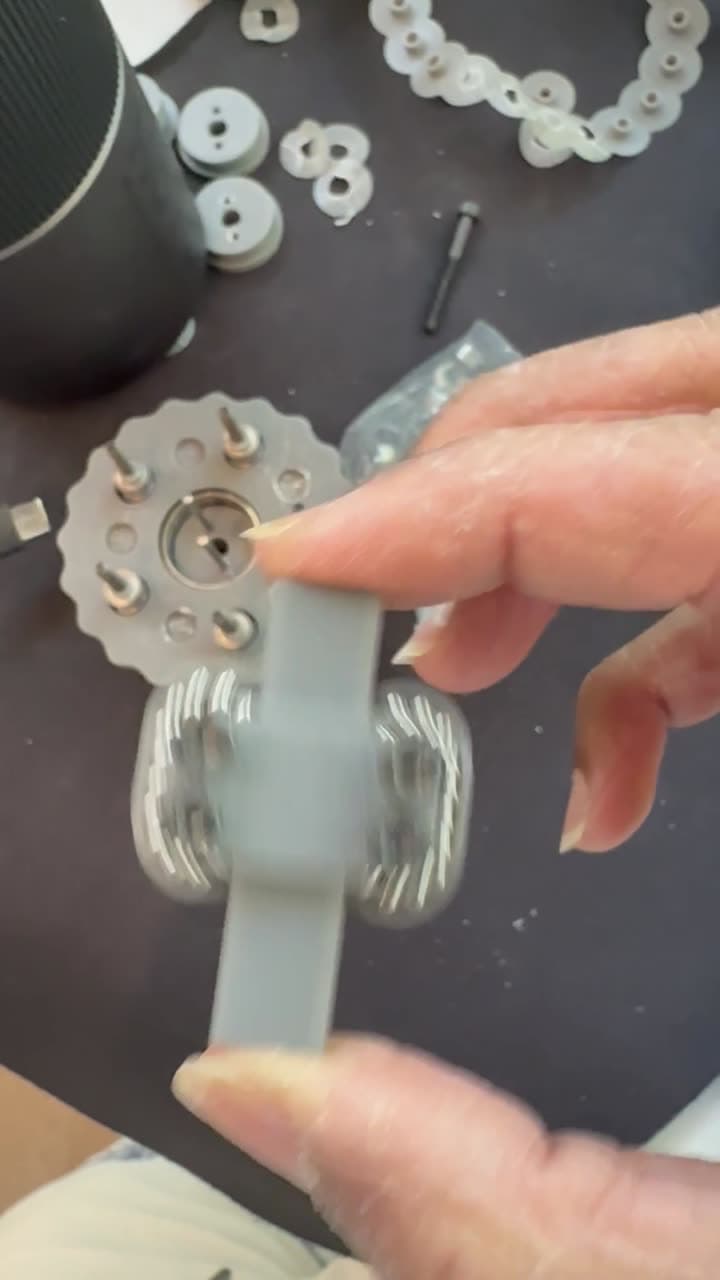
video
Full Build Vlog
The build in chronological order, from the earliest mechanisms through the assembled and fully extended arm.
Solo project
A ground-up six-axis manipulator designed and being built entirely in under 30 days, spanning custom actuators, structural links, sensing, wiring, and end-effector development.
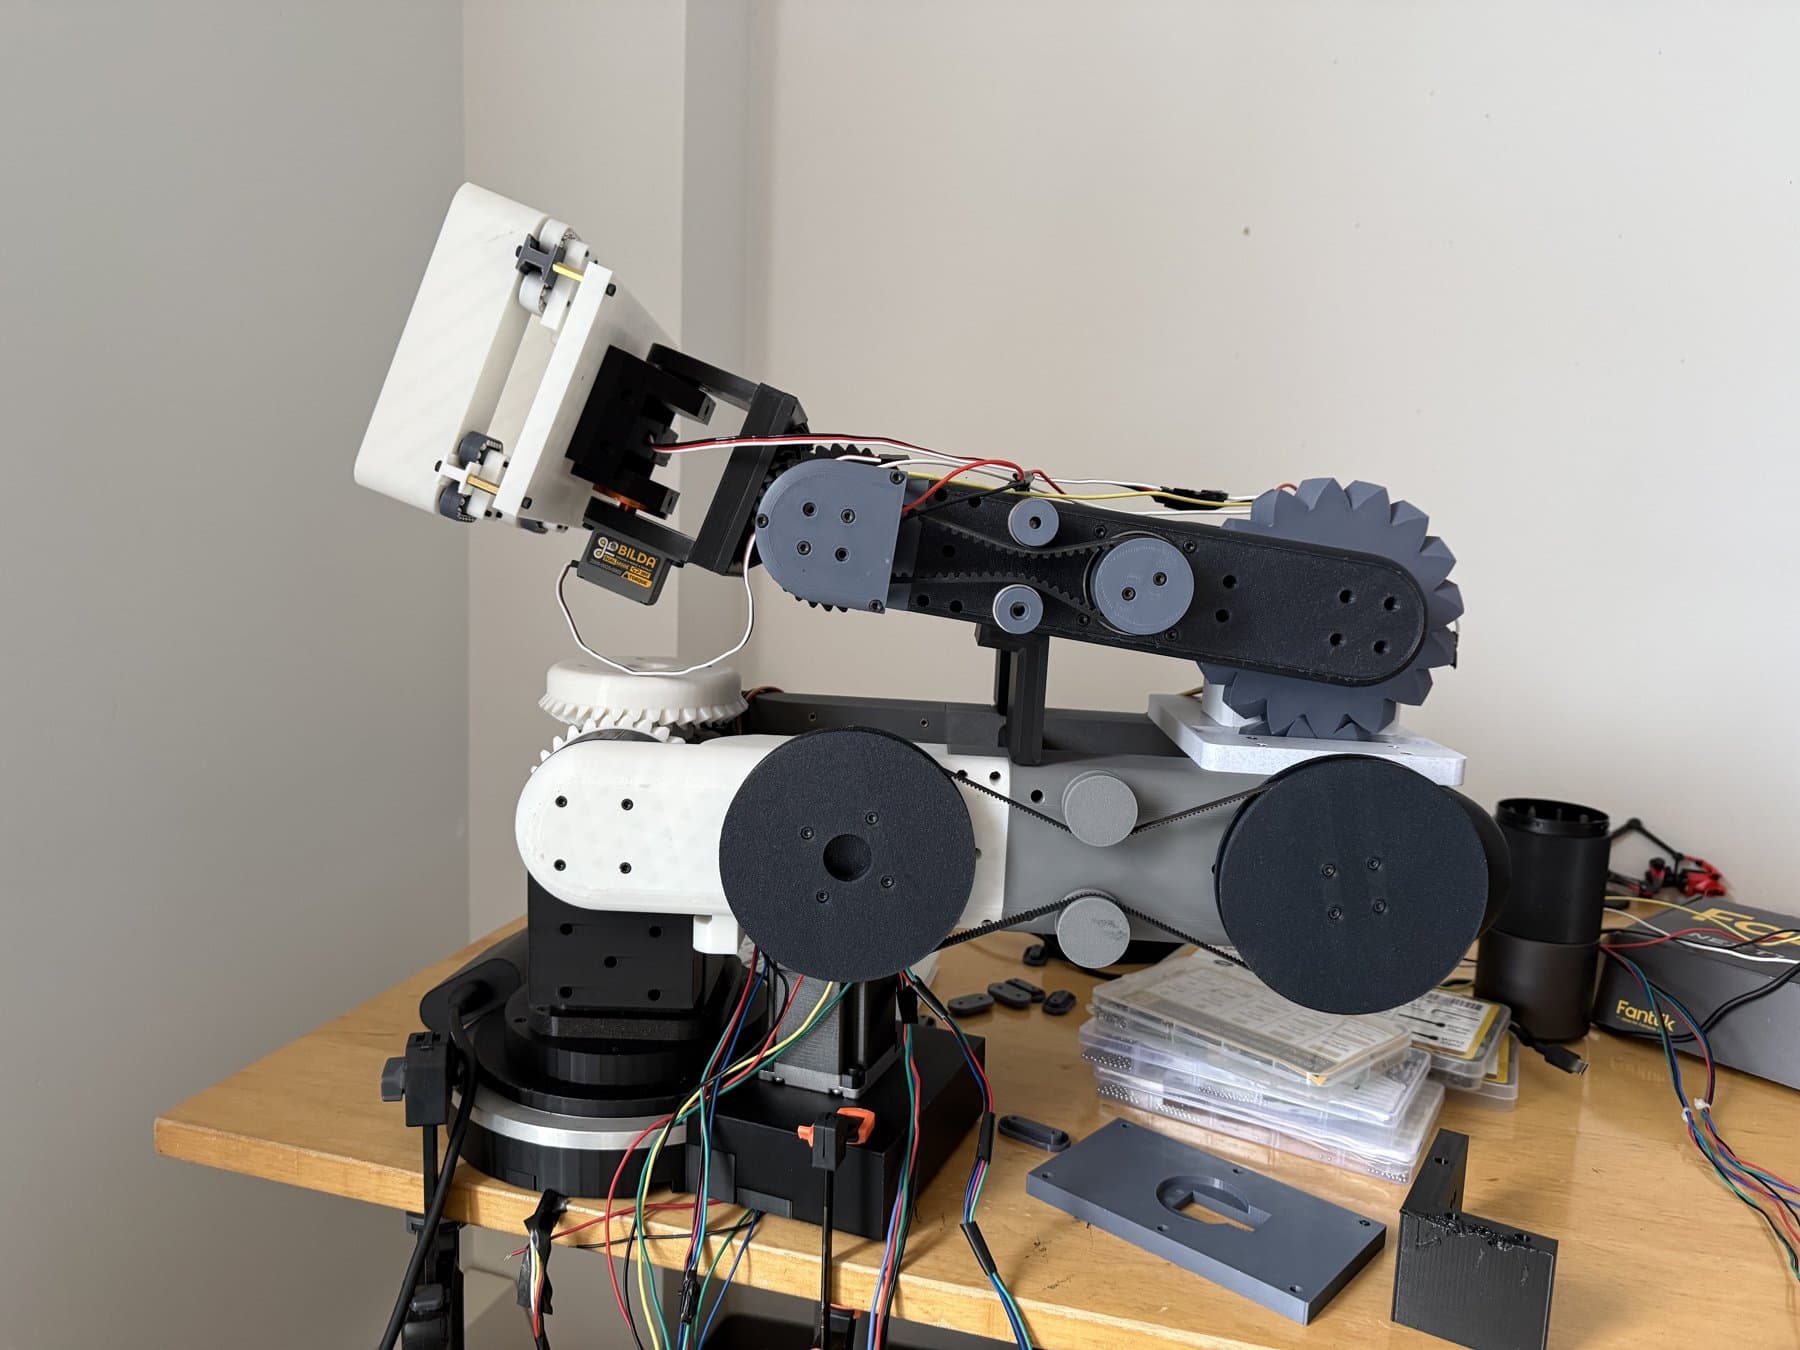
Build Log
A chronological build log following the arm from early actuator prototypes through the newer geared joints, assembly, claw development, and final assembled poses.
The build in chronological order, from the earliest mechanisms through the assembled and fully extended arm.
Subsystems
Each subsystem is its own build, with its own iteration history and demos. Open one to go deeper.