Overview
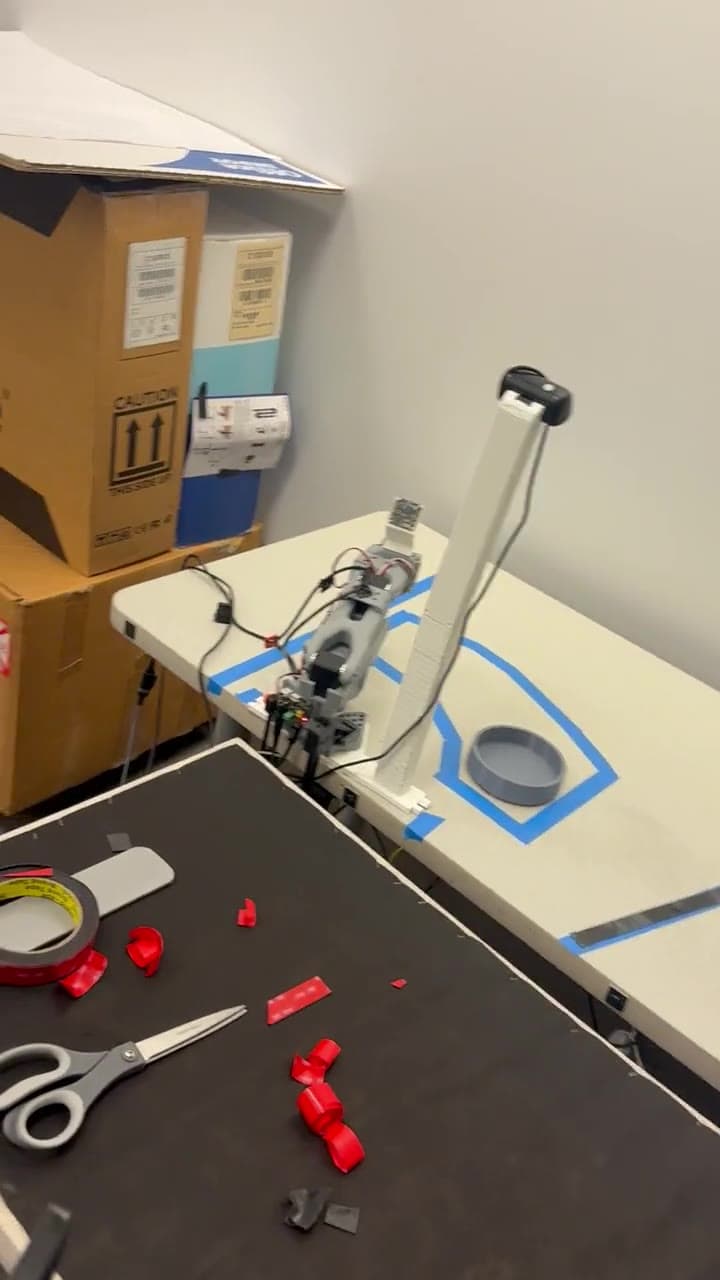
Growing out of manipulation work at Chimera Research, this project drives an SO-101 arm through a visible pick-and-place task end to end.
Solo project
Robotic manipulation demo using OpenCV tracking and hand-calculated inverse kinematics to guide an SO-101 arm through pick-and-place behavior.
Project Summary
A short look at the build, the main technical choices, and the pieces I iterated along the way.
Growing out of manipulation work at Chimera Research, this project drives an SO-101 arm through a visible pick-and-place task end to end.
I developed OpenCV tracking, mapped tracked object positions into encoder-space targets, and implemented inverse kinematics by hand for the SO-101 arm.
The project connects perception, hand-derived kinematics, encoder-space control targets, and manipulation benchmarking in a compact pick-and-place demo.
Demos
Videos and images from the current build, earlier iterations, and the small details that shaped the project.